On a a pharmaceutical packaging line, a six-axis articulated arm seemed like the obvious solution for placing bottles into their slots. After a few weeks, positioning discrepancies at the end of the stroke necessitated frequent recalibrations.
Replacing it with a Cartesian robot eliminated the problem: three linear axes, straight trajectories, and consistent repeatability over thousands of cycles. This type of situation illustrates why the industrial Cartesian robot remains a production choice, not a default choice.
Mechanical rigidity and repeatability on linear axes
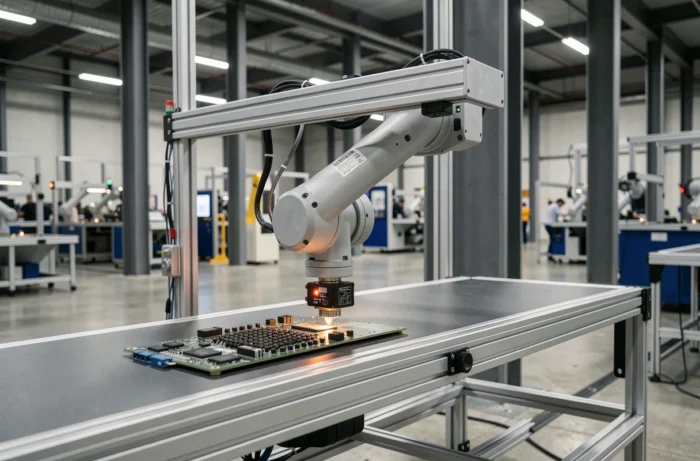
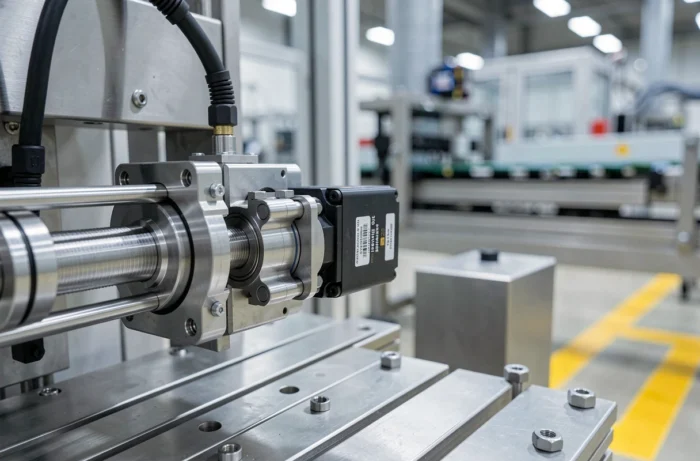
A Cartesian robot moves along orthogonal X, Y, and Z axes, each guided by a rail or a ball screw. This architecture eliminates the angular play found in the rotary joints of articulated arms. In a palletizing or dosing operation, repeatability does not degrade with the extension of the stroke, which changes the game for large working envelopes.
There is also a maintenance advantage: each axis can be disassembled and replaced independently. A failing motor on the Y axis does not require the entire system to be taken down. For production teams managing their own downtime, this is a concrete criterion. Obtaining a quote for an industrial Cartesian robot also allows for precise sizing of each axis based on the targeted load and speed.
Feedback varies on the issue of speed at the end of the stroke: some integrators report vibrations on long gantries if the sizing of the guides is not appropriate. The choice of rail profile and type of drive (timing belt or rack and pinion) remains a case-by-case decision.
Cartesian robot or articulated arm: concrete selection criteria
The question is not posed in terms of absolute superiority. It depends on the task. An articulated arm excels when it needs to reach points in a complex three-dimensional space, navigate around obstacles, or work on differently oriented parts. The Cartesian robot, on the other hand, dominates as soon as the movement is linear and the load moves on a defined plane.
- Pick-and-place on conveyor: the Cartesian covers the entire width of the belt without dead zones, and its programming boils down to X-Y-Z coordinates without inverse kinematics calculations.
- Dosing and screwing: the rigidity of the structure prevents micro-oscillations at the end of the trajectory, a common flaw in lightweight articulated arms used at high speeds.
- Palletizing heavy loads: a steel Cartesian gantry supports masses that most articulated arms of equivalent range cannot lift at the end of the arm without losing precision.
- Assembly in clean rooms: fewer exposed lubrication points, fewer emitted particles, which simplifies the qualification of the environment.
However, if the cell requires frequent tool rotations or access from underneath the part, the Cartesian shows its limits. A rotary axis is then added at the end of the gantry, but this complicates the whole system and reduces the simplicity advantage.
Modular gantry: the Cartesian robot as an automation platform
Recent market studies describe a clear evolution: the Cartesian robot is no longer limited to the role of a linear manipulator. It is becoming a modular platform connected to vision, sensors, and industrial networks. We now talk about modular gantries capable of adapting to lines with high product variability, short cycles, and frequent series changes.
In practical terms, this means that the same gantry can receive a vacuum gripper in the morning for packaging, and then a dimensional control tool in the afternoon. The standardization of mechanical and electrical interfaces between modules makes these reconfigurations quick. For an industrial SME producing in small series, this flexibility reduces the number of dedicated machines on the shop floor.
Vision and sensor integration
Adding a camera on the Z axis allows for real-time correction of the part’s positioning without mechanical recalibration. Coupled with an industrial communication system (EtherCAT, Profinet), the Cartesian robot sends its cycle, effort, and position data to a supervisor. This results in piece-by-piece traceability, required in the automotive and medical sectors.
Safety of Cartesian cells and ISO 10218 standards
The ISO 10218-1 and ISO 10218-2 standards were revised in 2025, replacing the 2011 editions still cited in many documents. These new versions introduce a classification of robots by level of danger and requalify collaborative modes: monitored stop, manual guidance, speed and separation monitoring, power and force limitation.
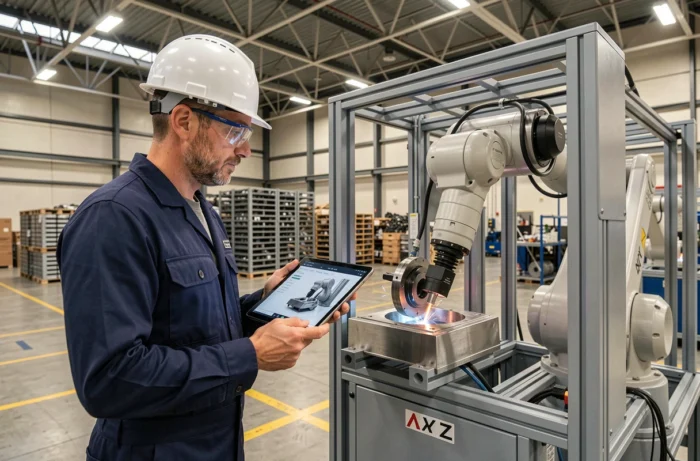
For a Cartesian robot, the impact is direct on the design of the cell. Physical guards (grilles, covers) must be sized according to the required safety performance level, and laser area scanners are increasingly replacing traditional immaterial barriers. An open gantry on two sides for operator loading now requires a documented risk analysis according to the new classification.
What this changes in practice
- Safety functions (emergency stop, speed limitation in shared areas) must achieve a performance level defined by the standard, verified by calculation and testing.
- The collaborative mode “speed monitoring and separation” applies well to Cartesian robots, whose straight trajectories are easier to model than those of an articulated arm.
- The interlocking of guards must integrate a fault diagnosis, which requires certified components and specific wiring.
Ignoring this normative update exposes one to a refusal of CE compliance during the integration of the cell. Integrators who still size their protections according to the 2011 edition take a real risk on projects delivered from this year onward.
The Cartesian robot remains a technical solution whose value lies in its mechanical simplicity and predictability. Its strength is not in being versatile, but in being reliable where the trajectory is known. With the evolution towards modular platforms and the tightening of normative requirements, the choice of a Cartesian gantry is now made based on both industrial flexibility criteria and the sole precision of positioning.